I am an undergraduate student at Seoul National University (SNU), majoring in Electrical and Computer Engineering with a minor in Mechanical Engineering.
I am currently a researcher at CONFIG, advised by Kimin Lee and Hyungmok Son. Previously, I conducted research with Xiaolong Wang and Sha Yi at UC San Diego. At SNU, I have also worked with Frank Chongwoo Park and Yong-Lae Park.
GPA: Seoul National University: 3.89/4.0 | UC San Diego: 4.0/4.0
I am applying to PhD programs for Fall 2027.
I study how robots can leverage human sensory modalities, such as vision and tactile, to learn human-like manipulation.
I aim to enable robots to learn physical dynamics through interaction. By coupling active perception with uncertainty-aware planning and control, I study how robots can use tactile, force feedback, and proprioception to refine their models and adapt their actions in real time. Ultimately, I seek to turn accumulated experience into generalizable physical knowledge for human-like manipulation, with the broader goal of enabling robots to execute complex tasks and assist people.
Publications
Click any image or video to enlarge.Junsung Park, Jaehwi Song, Byeongguk Jeon, Suchae Jeong, Sungdong Kim, Minjoon Seo, Hyungmok Son, and Kimin Lee
CVPR 2027, under review
Junsung Park*, Sachin Bhadang*, Carmelo Sferrazza, Sha Yi, and Xiaolong Wang
CoRL 2026
paper / project page / dataset
Junsung Park, Hogun Kee, and Songhwai Oh
RSS 2026, Workshop: Tactile Sensing for Robotic Foundation Models
paper
Junsung Park
IEEE MIT URTC, 2025
paper
Anya Zorin, Zilin Si, Myungsun Park, Junsung Park, Alexiy Buynitsky, Sachin Bhadang, Taejun Park, Sohee John Yoon, Yong-Lae Park, Oliver Kroemer, Zeynep Temel, Michael T. Tolley, Sha Yi, and Xiaolong Wang
Preprint, 2026
paper
Projects
Junsung Park
Course project, continued after UCSD ECE 276B, 2026
project page
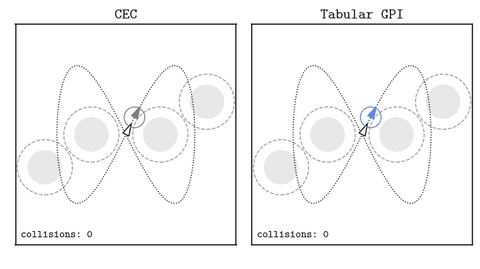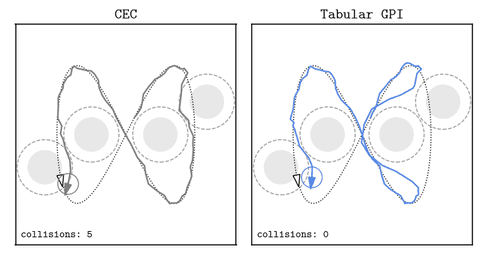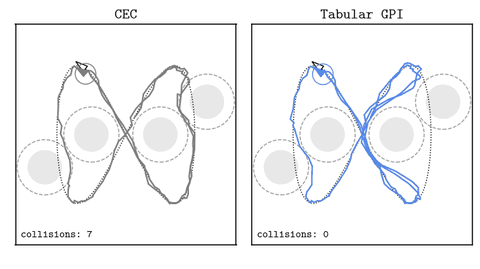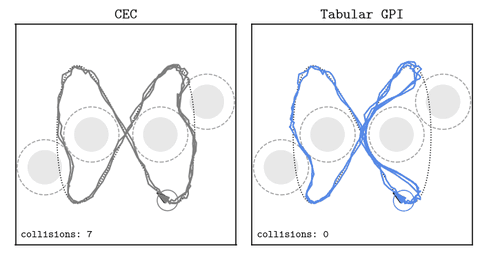
Compared receding-horizon CEC with policy iteration under motion noise, and built a CEC–GPI hybrid with path-aware collision risk that tracks closer while staying safe.
Junsung Park, Injae John, Sungjae Hwang, Yong-Lae Park
Soft Robotics & Bionics Lab (SRBL), Seoul National University, 2024
Developed a wearable rehabilitation glove for stroke patients, integrating a rack-and-pinion actuator, e-gain soft sensor, and IMU-based feedback control to provide adaptive thumb motion assistance.
Junsung Park
Open Source Project & Dataset, 2025
dataset
Built a large-scale multimodal dataset-generation pipeline integrating Robosuite, RoboCasa, and cuRobo, producing synchronized RGB-D, contact-force, and proprioceptive data for training foundation robot policies.
Junsung Park
Humanoid Imitation Learning Project, 2025
Developed a whole-body imitation learning pipeline that retargets human–object interaction motions from the OMOMO Dataset to the Unitree G1 using SMPL-based preprocessing and gradient optimization.
Junsung Park, Hyuntae Hwang, Seungha Woo, Minjae Lee
Mechatronics Design Competition, Awarded, 2023
Developed a centrifugal umbrella system that actively removes rainwater using a high-torque motor and rotational airflow. Led the system design and integration, achieving fast water removal, low noise, and portable operation.
Junsung Park
Scene Understanding & Mapping Project, 2025
Built a BEV mapping pipeline in AI2-THOR that converts egocentric RGB-D into depth-based semantic top-down maps. Implemented a Trans4Map-style egocentric-to-allocentric model for accurate online BEV scene reconstruction.